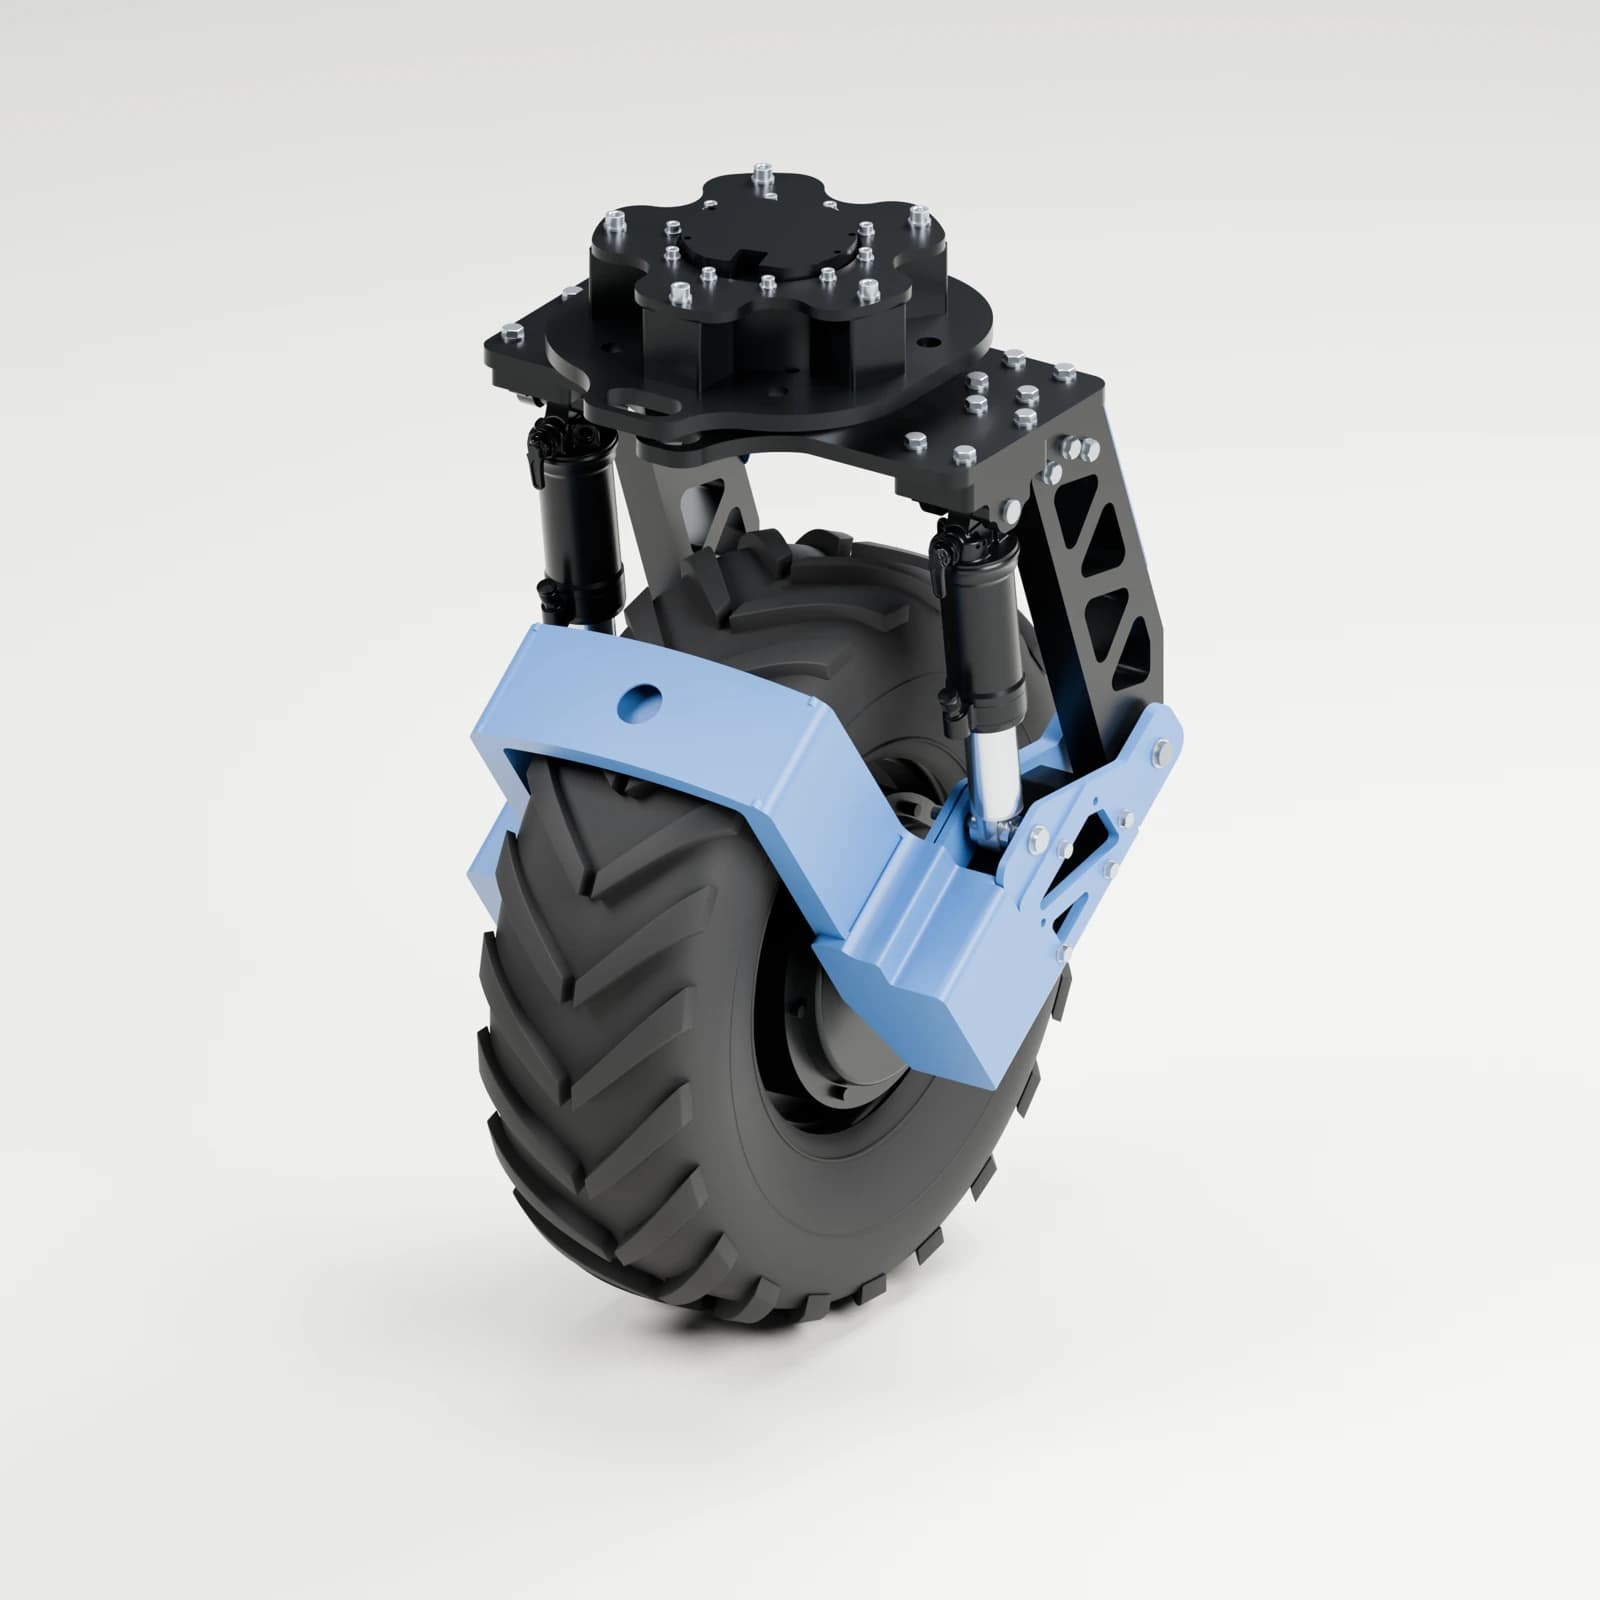
Three-quarter view — CAD render
Robotic drive systems
Suspended Swerve Module
A 48 V suspended swerve module with powered traction and steering, adjustable air suspension, and a rated capacity of 350 lb per corner.
Pricing on inquiry
You’ll send your contact details with your cart. Product details and pricing are confirmed by our team.
Product details
The R1 Systems Suspended Swerve Module combines powered traction, powered steering, and adjustable air suspension in one assembly for robotic platforms. Each module is rated for 350 lb per corner and weighs approximately 64 lb. The package includes an ODrive S1 drive controller, wiring harness, and control software. The geared traction hub uses an 8-inch rim with a 16-inch OD tubeless tractor tire. The traction motor is advertised at 1,000 W rated power, with 200 N·m peak torque and a maximum wheel speed of 120 rpm at 48 V under light load. Peak torque and maximum speed describe different operating points. Powered steering uses dual 14-bit encoders, CAN communication, and field-oriented control. Air spring/damper shocks provide 55 mm of shock stroke and 3 inches of overall vertical wheel travel. Air pressure is adjustable from 30 to 120 psi, with adjustable lockout and rebound rate. Caster offset ranges from −1.5 to +1.5 inches across suspension travel and is zero at mid-stroke. The included software provides a local commissioning workbench, C/C++ and Python interfaces, and ROS 2 integration. The current software is a preview release; application-specific setup and tuning remain part of integration. Nominal system voltage is 48 V; battery full-charge and regenerative voltage must stay within the ODrive S1 controller's 50.5 V DC input limit. Optional accessories include a USB-to-CAN configuration adapter and a custom Anderson-to-power-bus cable. Specify accessory quantities and integration requirements with your inquiry. CAD images illustrate the current assembly and its finishes.
Available to order. Pricing and lead time by inquiry.
| Rated capacity | 350 lb per corner |
|---|---|
| Nominal voltage | 48 V |
| Module weight | Approximately 64 lb |
| Rated motor power | 1,000 W (supplier advertised rating) |
|---|---|
| Peak torque | 200 N·m |
| Gear reduction | 10:1 |
| Maximum wheel speed | 120 rpm at 48 V (light load) |
| Rim diameter | 8 in |
| Tire outside diameter | 16 in |
| Tire specification | 16×6.5-8 tubeless tractor tire |
| Encoder resolution | 10-bit |
| Additional feedback | Hall sensor |
| Peak torque | 120 N·m |
|---|---|
| Gear reduction | 9:1 |
| No-load speed | 200 rpm |
| Encoder feedback | Dual 14-bit encoders |
| Communication | CAN |
| Motor control | Field-oriented control (FOC) |
| Shock stroke | 55 mm |
|---|---|
| Vertical wheel travel | 3 in |
| Caster offset range | ±1.5 in; zero at 50% suspension stroke |
| Shock absorber | Air spring/damper |
| Lockout | Adjustable |
| Rebound rate | Adjustable |
| Air pressure | 30–120 psi, adjustable |